Collisions — Explained
Detailed Explanation
Collisions represent a fundamental class of physical interactions where objects exert significant forces on each other over a relatively short duration, leading to changes in their individual momenta and, potentially, their kinetic energies.
Analyzing collisions requires a deep understanding of conservation laws and the concept of impulse.\n\n1. Conceptual Foundation: Impulse and Impulse-Momentum Theorem\nBefore delving into the types of collisions, it's essential to understand the concept of impulse.
When objects collide, they exert large forces on each other for a brief period. The effect of this force over time is quantified by impulse.\n* Impulse (J): Impulse is defined as the product of the average force acting on an object and the time interval over which the force acts.
It is a vector quantity, having the same direction as the force.\n \n The unit of impulse is Newton-second (N\cdot s), which is equivalent to kilogram-meter per second (kg\cdot m/s), the unit of momentum.
\n* Impulse-Momentum Theorem: This theorem states that the impulse acting on an object is equal to the change in its linear momentum.\n \n This theorem is incredibly useful because it links the forces acting during a collision (which are often difficult to measure directly) to the observable changes in momentum.
During a collision, the internal forces between the colliding bodies are typically much larger than any external forces (like gravity or friction) for the short duration of the impact. This allows us to treat the colliding bodies as an isolated system for momentum conservation purposes.
\n\n2. Key Principles and Laws: Conservation of Linear Momentum\nThe most fundamental principle governing all collisions is the conservation of linear momentum. For a system of two or more particles, if no external forces act on the system, the total linear momentum of the system remains constant.
\n* Mathematical Statement: For a two-body collision (masses with initial velocities and final velocities ):\n \n This equation holds true for all types of collisions (elastic, inelastic, perfectly inelastic) and in any number of dimensions.
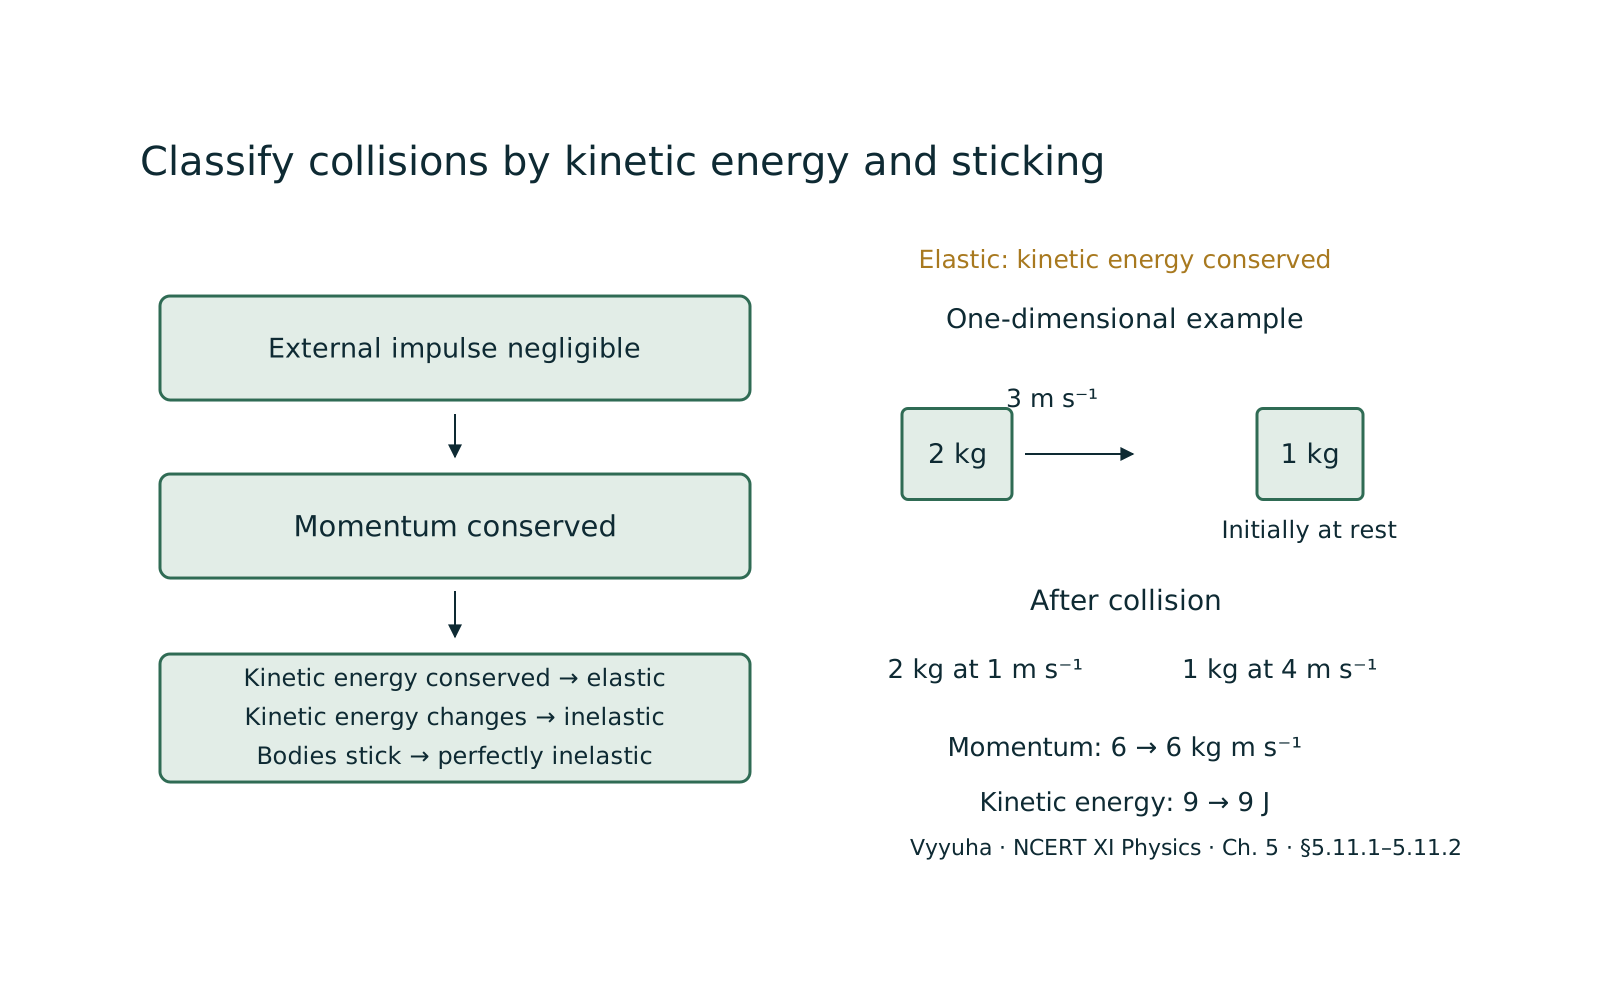
For 2D or 3D collisions, this vector equation must be resolved into components along perpendicular axes (e.g., x and y axes), and momentum must be conserved independently along each axis.\n\n3. Classification of Collisions based on Kinetic Energy\nWhile momentum is always conserved in an isolated system, kinetic energy may or may not be.
This distinction leads to the classification of collisions.\n* Elastic Collisions:\n * Definition: Both linear momentum and total kinetic energy are conserved.\n * Characteristics: The colliding bodies regain their original shape completely after the collision.
No energy is lost to deformation, heat, or sound.\n * Coefficient of Restitution (e): For an elastic collision, . The coefficient of restitution is defined as the ratio of the relative speed of separation to the relative speed of approach:\n \n where is the relative velocity of separation and is the relative velocity of approach.
The negative sign ensures 'e' is positive, as and typically have opposite signs.\n * 1D Elastic Collision Derivations: For a head-on (1D) elastic collision between two masses and with initial velocities and , and final velocities and , we have two conservation equations:\n 1.
Momentum: \n 2. Kinetic Energy: \n Solving these two equations simultaneously yields the final velocities:\n \n \n Special Cases for 1D Elastic Collisions:\n * If : and .
The bodies exchange velocities.\n * If and : and . The lighter body rebounds with nearly its initial speed, and the heavier body remains almost at rest (e.
g., a ball hitting a wall).\n * If and : and . The heavier body continues with its initial speed, and the lighter body moves with twice the speed of the heavier body (e.
g., a truck hitting a stationary bicycle).\n\n* Inelastic Collisions:\n * Definition: Linear momentum is conserved, but total kinetic energy is not conserved. Some kinetic energy is transformed into other forms (heat, sound, deformation).
Total energy, however, is always conserved.\n * Characteristics: The colliding bodies may deform permanently. The relative speed of separation is less than the relative speed of approach.\n * Coefficient of Restitution (e): For an inelastic collision, .
\n * Loss of Kinetic Energy: The loss of kinetic energy is given by .\n\n* Perfectly Inelastic Collisions:\n * Definition: A special case of inelastic collision where the colliding bodies stick together after impact and move as a single combined mass.
\n * Characteristics: Maximum possible loss of kinetic energy (while still conserving momentum). The relative speed of separation is zero.\n * Coefficient of Restitution (e): For a perfectly inelastic collision, .
\n * 1D Perfectly Inelastic Collision: If and stick together and move with a common final velocity :\n \n \n\n**4.
Two-Dimensional Collisions**\nIn 2D collisions, the objects do not move along the same straight line before and after the collision. Momentum conservation must be applied vectorially, meaning it must hold true for each component (e.
g., x and y components) independently.\n* Conservation of Momentum (2D):\n \n This resolves into:\n * x-component: \n * y-component: \n* Kinetic Energy (2D): If the collision is elastic, kinetic energy is also conserved:\n \n Solving 2D collision problems often involves trigonometry to resolve velocities into components and then solving a system of equations.
\n\n5. Real-World Applications\nCollisions are ubiquitous in nature and technology:\n* Sports: Billiards, bowling, cricket (bat-ball interaction), football tackles. Understanding momentum transfer is key to optimizing performance and safety.
\n* Automotive Safety: Car crashes are inelastic collisions. Engineers design crumple zones to increase the collision time, thereby reducing the average force on occupants (from ), and airbags to spread the impact force over a larger area.
\n* Nuclear Physics: Collisions between subatomic particles (e.g., in particle accelerators) are often elastic or involve transformations of mass into energy (relativistic collisions).\n* Astronomy: Collisions between celestial bodies (asteroids, comets) shape planetary systems.
\n* Engineering: Design of protective gear, shock absorbers, and impact-resistant materials.\n\n6. Common Misconceptions\n* "Kinetic energy is always conserved in collisions." This is false.
Kinetic energy is only conserved in elastic collisions. In inelastic collisions, it is converted to other forms of energy.\n* "Momentum is only conserved in elastic collisions." This is also false.
Linear momentum is conserved in all types of collisions, provided the system is isolated from external forces.\n* "Collisions always involve direct contact." While most common collisions do, the definition includes interactions where strong forces are exerted over a small distance, even without direct physical contact (e.
g., electrostatic repulsion between charged particles, or gravitational slingshot maneuvers). However, for NEET, direct contact is usually implied.\n* **"The coefficient of restitution 'e' is always between 0 and 1.
"** While true for typical macroscopic collisions, 'e' can theoretically be greater than 1 if energy is added to the system during the collision (e.g., an explosion), though such cases are not usually considered 'collisions' in the standard sense for NEET.
\n\n7. NEET-Specific Angle\nFor NEET, collision problems frequently test your ability to:\n* Identify the type of collision: Elastic, inelastic, or perfectly inelastic, as this dictates which conservation laws (momentum and/or kinetic energy) apply.
\n* Apply conservation of momentum: Correctly set up the vector equation for momentum conservation, especially for 2D problems, resolving into components.\n* Use the coefficient of restitution: Understand its definition and how to apply it to find unknown velocities.
\n* Calculate energy loss: For inelastic collisions, be able to calculate the amount of kinetic energy lost.\n* Solve for unknown velocities: Often, you'll be given initial conditions and asked to find final velocities, or vice-versa.
\n* Analyze special cases: Be familiar with scenarios like a light mass hitting a heavy mass, or equal masses colliding, as these often simplify calculations. Bullet-block problems (ballistic pendulum) are a classic perfectly inelastic collision scenario.
Mastering these aspects requires consistent practice with a variety of problem types, paying close attention to vector directions and the specific conditions of each collision.
Often confused with
Side-by-side differences the NEET paper likes to test.
| Aspect | Collisions | Inelastic Collisions |
|---|---|---|
| Conservation of Linear Momentum | Always conserved (for an isolated system). | Always conserved (for an isolated system). |
| Conservation of Kinetic Energy | Conserved. | Not conserved; some kinetic energy is lost. |
| Coefficient of Restitution (e) | $e = 1$ | $0 \le e < 1$ |
| Deformation of Objects | No permanent deformation; objects regain original shape. | Permanent deformation may occur; objects may stick together. |
| Relative Speed of Separation vs. Approach | Relative speed of separation equals relative speed of approach. | Relative speed of separation is less than relative speed of approach. |
| Examples | Collisions of billiard balls (idealized), subatomic particles. | Car crashes, bullet embedding in wood, throwing a ball of clay at a wall. |
The fundamental distinction between elastic and inelastic collisions lies in the fate of kinetic energy. While linear momentum is conserved in both types (assuming an isolated system), kinetic energy is conserved only in elastic collisions.
In inelastic collisions, kinetic energy is transformed into other forms like heat, sound, or internal energy due to deformation. This difference is quantitatively captured by the coefficient of restitution, 'e', which is 1 for elastic collisions and between 0 and 1 (inclusive) for inelastic collisions.
Understanding this distinction is vital for correctly applying the relevant conservation laws in problem-solving.
Why it is tested: For NEET, distinguishing between elastic and inelastic collisions is paramount. Many problems hinge on correctly identifying the collision type to determine whether kinetic energy conservation can be applied alongside momentum conservation. Questions frequently test the calculation of energy loss in inelastic collisions or the application of the coefficient of restitution to find final velocities. Recognizing the implications of 'e' values is a common test of conceptual understanding.
Questions students ask
5 answered on this topic.
What is the difference between an elastic and an inelastic collision?
The primary difference lies in the conservation of kinetic energy. In an elastic collision, both linear momentum and total kinetic energy of the system are conserved. The objects rebound without any permanent deformation, and no energy is lost as heat, sound, or internal energy.
In contrast, in an inelastic collision, linear momentum is conserved, but total kinetic energy is not. Some kinetic energy is converted into other forms, such as heat, sound, or energy of deformation.
The objects may deform permanently or even stick together (perfectly inelastic collision).
Is momentum always conserved in a collision?
Yes, linear momentum is always conserved in any type of collision (elastic, inelastic, or perfectly inelastic), provided the system of colliding objects is isolated, meaning no net external force acts on it. The forces involved in the collision itself are internal forces within the system, and they cancel out in pairs according to Newton's third law, thus not changing the total momentum of the system. This is a fundamental principle derived from Newton's laws of motion.
What is the coefficient of restitution and what does it tell us?
The coefficient of restitution, denoted by 'e', is a dimensionless quantity that quantifies the elasticity of a collision. It is defined as the ratio of the relative speed of separation of the colliding bodies after impact to their relative speed of approach before impact.
Mathematically, . For a perfectly elastic collision, (relative speeds are equal). For a perfectly inelastic collision (objects stick together), (relative speed of separation is zero).
For all other inelastic collisions, . It essentially tells us how much kinetic energy is retained after a collision.
Can kinetic energy increase after a collision?
In standard collision scenarios, where only the kinetic energy of the colliding bodies is considered, kinetic energy generally decreases or remains constant. However, if there's an internal source of energy within the system that gets released during the interaction (like an explosion), the kinetic energy of the system can increase.
Such events are sometimes referred to as 'superelastic' or 'explosive' collisions, where the coefficient of restitution can be greater than 1. For typical NEET problems, assume kinetic energy either remains constant (elastic) or decreases (inelastic).
How do I approach a 2D collision problem?
For a 2D collision, the key is to apply the conservation of linear momentum independently along two perpendicular axes (usually x and y). First, draw a clear diagram showing initial and final velocities with their angles.
Resolve all initial and final velocity vectors into their x and y components. Then, write separate conservation of momentum equations for the x-components and y-components. If the collision is elastic, you can also use the conservation of kinetic energy equation.
This will give you a system of equations to solve for the unknown velocities or angles.