Equilibrium — Explained
Detailed Explanation
The concept of equilibrium is a cornerstone of classical mechanics, directly stemming from Newton's First Law of Motion. It describes a state of balance where an object's motion, both linear and rotational, remains unchanged.
For a NEET aspirant, a deep understanding of equilibrium is crucial for solving problems involving forces, torques, and stability in various physical systems.\n\n### Conceptual Foundation: Linking to Newton's First Law\nNewton's First Law, often called the Law of Inertia, states that an object at rest stays at rest, and an object in motion stays in motion with the same speed and in the same direction unless acted upon by an unbalanced force.
The 'unbalanced force' is what we refer to as the 'net force' or 'resultant force'. When this net force is zero, the object's acceleration is zero. This implies that its velocity is constant. If the constant velocity is zero, the object is in static equilibrium.
If the constant velocity is non-zero, the object is in dynamic equilibrium.\n\nHowever, Newton's First Law primarily addresses translational motion (motion along a line or curve). For a complete state of equilibrium, we must also consider rotational motion.
Just as an unbalanced force causes translational acceleration, an unbalanced 'torque' causes rotational acceleration (angular acceleration). Therefore, for an object to be in complete equilibrium, its rotational state must also be constant, meaning the net torque acting on it must be zero.
\n\n### Key Principles and Laws of Equilibrium\nFor an object to be in equilibrium, two fundamental conditions must be satisfied:\n\n1. Translational Equilibrium: The vector sum of all external forces acting on the object must be zero.
\n
\n\n2. Rotational Equilibrium: The vector sum of all external torques (or moments) acting on the object about any arbitrary pivot point must be zero.\n
g., positive for counter-clockwise, negative for clockwise). The choice of the pivot point is arbitrary; if an object is in rotational equilibrium about one point, it is in rotational equilibrium about all points.
Choosing a pivot point strategically (e.g., at a point where an unknown force acts) can simplify calculations by eliminating the torque due to that force.\n\n### Types of Equilibrium\nEquilibrium can be classified based on the object's state of motion and its response to small displacements:\n\n**A.
Based on State of Motion:**\n* Static Equilibrium: The object is at rest and remains at rest. Its linear velocity is zero () and its angular velocity is zero (). Example: A book on a table, a bridge standing still.
\n* Dynamic Equilibrium: The object is moving with a constant linear velocity () and/or a constant angular velocity (). Example: A satellite orbiting Earth at a constant speed, a car moving at a constant speed on a straight road, a fan rotating at a constant angular speed.
\n\nB. Based on Stability (for static equilibrium): This classification describes how an object behaves when slightly displaced from its equilibrium position.\n* Stable Equilibrium: If, when slightly displaced, the object tends to return to its original equilibrium position.
This occurs when the center of gravity (CG) is at its lowest possible position. Example: A cone resting on its base. If you tilt it slightly, it will wobble and return to its original position.\n* Unstable Equilibrium: If, when slightly displaced, the object tends to move further away from its original equilibrium position.
This occurs when the CG is at its highest possible position. Example: A cone balanced on its tip. A tiny nudge will cause it to fall over.\n* Neutral Equilibrium: If, when slightly displaced, the object remains in its new position, finding a new equilibrium state.
This occurs when the CG's height does not change upon displacement. Example: A sphere on a flat surface. If you roll it, it will stop at a new position and be in equilibrium there.\n\n### Derivations and Applications\nWhile there aren't complex 'derivations' of the equilibrium conditions themselves, the application involves setting up equations based on free-body diagrams (FBDs).
For a typical 2D problem, you would:\n1. Draw an FBD: Isolate the object and draw all external forces acting on it, indicating their directions and points of application.\n2. Choose a Coordinate System: Select appropriate x and y axes.
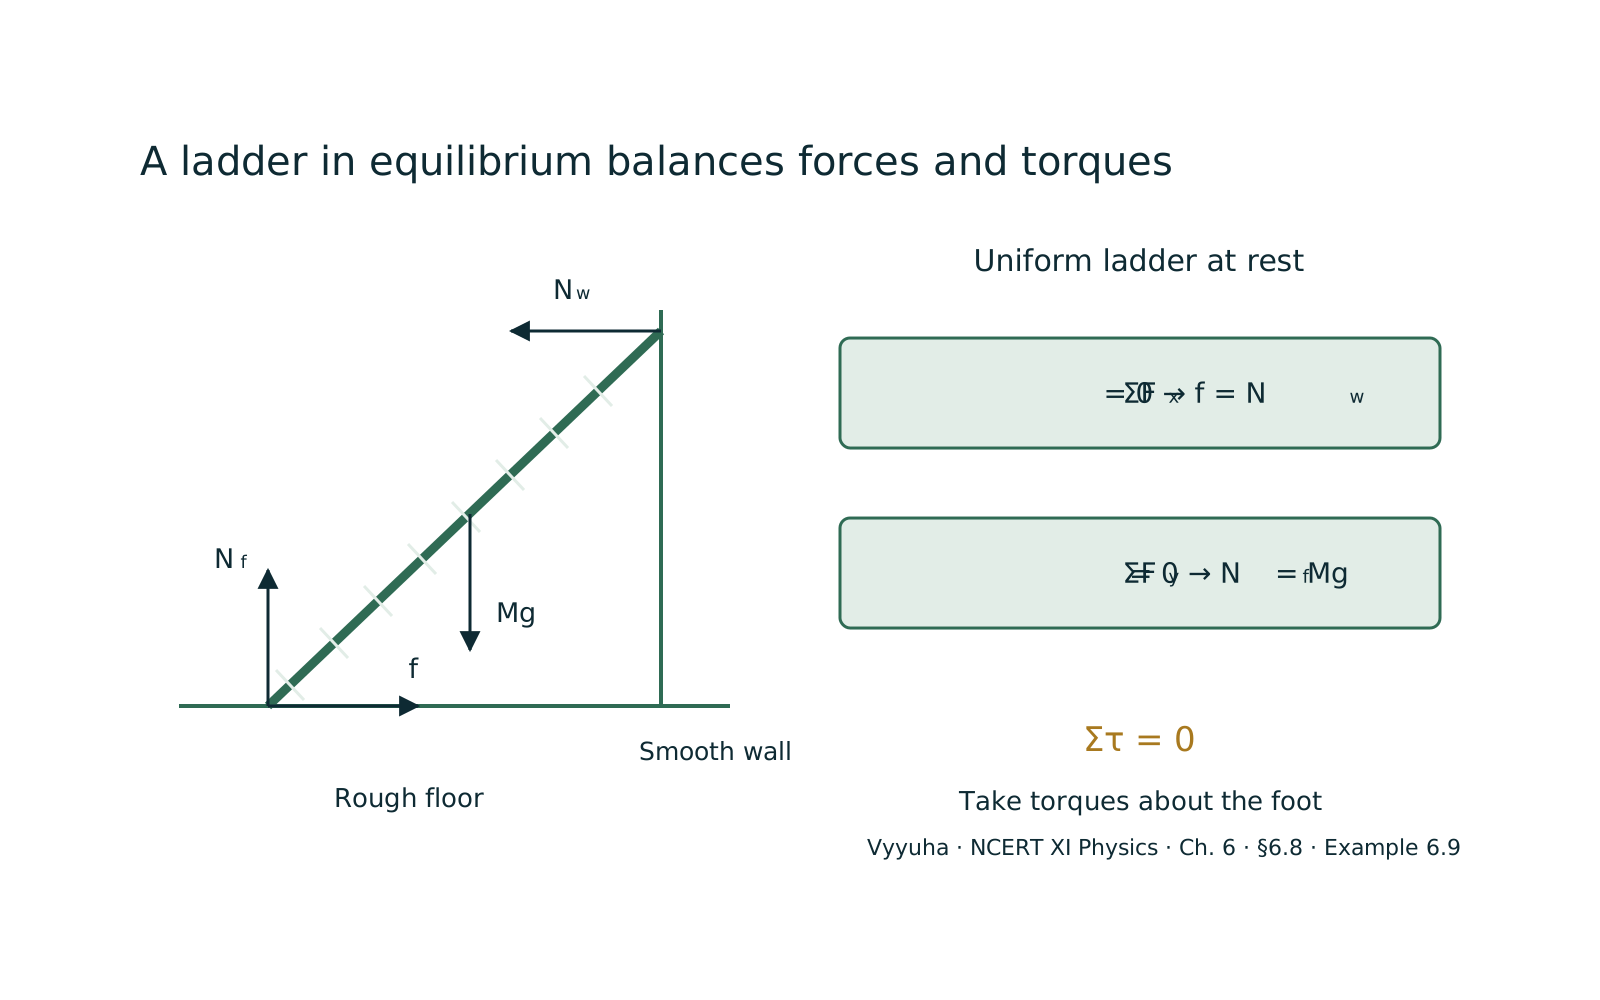
Resolve any forces not aligned with these axes into components.\n3. Apply Translational Equilibrium Conditions: Set the sum of forces in the x-direction to zero () and the sum of forces in the y-direction to zero ().
\n4. Choose a Pivot Point: For rotational equilibrium, select a convenient pivot point. Often, choosing a point where an unknown force acts simplifies calculations as that force's torque about that point will be zero.
\n5. Apply Rotational Equilibrium Condition: Set the sum of torques about the chosen pivot point to zero (). Remember to assign signs to torques (e.g., counter-clockwise positive, clockwise negative).
\n6. Solve the System of Equations: You will typically have a system of 2 or 3 linear equations (for 2D problems) that can be solved simultaneously to find unknown forces or distances.\n\nReal-World Applications:\n* Architecture and Engineering: Designing stable bridges, buildings, and other structures relies entirely on ensuring they are in static equilibrium under various loads.
\n* Biomechanics: Analyzing the forces and torques in the human body, such as when standing, lifting, or performing exercises, to understand stability and prevent injury.\n* Vehicle Design: Ensuring cars, planes, and ships are stable and balanced, especially during turns or in turbulent conditions.
\n* Simple Machines: Levers, pulleys, and inclined planes often involve objects in equilibrium or moving at constant velocity.\n* Balancing Acts: Acrobats and tightrope walkers intuitively apply principles of stable equilibrium to maintain their balance.
\n\n### Common Misconceptions\n* Equilibrium means no forces are acting: This is incorrect. Equilibrium means the net force is zero. Individual forces can be very large, but they perfectly cancel each other out.
\n* Dynamic equilibrium implies acceleration: This is also incorrect. Dynamic equilibrium means constant velocity, which implies zero acceleration. Students often confuse 'motion' with 'acceleration'.
\n* Torque is the same as force: While related, torque is the rotational equivalent of force. Force causes linear acceleration, while torque causes angular acceleration. Torque depends on both the force magnitude and its perpendicular distance from the pivot (moment arm).
\n* The pivot point for torque calculation must be fixed: While often convenient, the pivot point can be chosen arbitrarily. If an object is in rotational equilibrium, the net torque is zero about any point.
\n\n### NEET-Specific Angle\nNEET questions on equilibrium often involve:\n* Free-Body Diagrams: The ability to correctly draw an FBD and identify all forces (tension, normal force, friction, gravity) is paramount.
\n* Vector Resolution: Resolving forces into components along chosen axes is a frequent step, especially for inclined planes or forces at angles.\n* Torque Calculations: Problems involving levers, ladders leaning against walls, or objects suspended by multiple strings often require applying the rotational equilibrium condition.
\n* Identifying Types of Equilibrium: Conceptual questions might ask to identify stable, unstable, or neutral equilibrium from a given scenario.\n* System of Equations: Solving for multiple unknowns (e.
g., tensions in strings, normal forces, friction) by setting up and solving simultaneous equations from the equilibrium conditions.\n* Conceptual Understanding: Distinguishing between static and dynamic equilibrium, and understanding that zero net force means constant velocity, not necessarily zero velocity.
Often confused with
Side-by-side differences the NEET paper likes to test.
| Aspect | Equilibrium | Dynamic Equilibrium |
|---|---|---|
| State of Motion | Object is at rest (linear velocity $v=0$, angular velocity $\omega=0$). | Object is in motion (linear velocity $v \neq 0$ and/or angular velocity $\omega \neq 0$). However, these velocities are constant. |
| Acceleration | Linear acceleration $a=0$, angular acceleration $\alpha=0$. | Linear acceleration $a=0$, angular acceleration $\alpha=0$. (This is the commonality - zero acceleration). |
| Net Force | $\Sigma \vec{F} = 0$ | $\Sigma \vec{F} = 0$ |
| Net Torque | $\Sigma \vec{\tau} = 0$ | $\Sigma \vec{\tau} = 0$ |
| Example | A book resting on a table, a bridge standing still. | A car moving at a constant speed on a straight road, a satellite in a stable orbit. |
Static equilibrium describes an object that is completely motionless, with zero linear and angular velocities, while dynamic equilibrium describes an object that is moving but with constant linear and angular velocities. The crucial commonality is that in both cases, the net force and net torque acting on the object are zero, leading to zero translational and rotational acceleration. The distinction lies purely in whether the constant velocity is zero or non-zero.
Why it is tested: NEET relevance: Understanding the distinction is vital for correctly interpreting problem statements and applying the equilibrium conditions. Misconceptions often arise when students assume 'equilibrium' always means 'at rest'.
Questions students ask
5 answered on this topic.
What is the primary difference between static and dynamic equilibrium?
The primary difference lies in the object's state of motion. In static equilibrium, the object is completely at rest, meaning both its linear velocity and angular velocity are zero and remain zero. An example is a book lying motionless on a table.
In dynamic equilibrium, the object is in motion, but its linear velocity and angular velocity are constant. This means it's moving without accelerating or decelerating, and rotating without speeding up or slowing down.
A car cruising at a steady speed on a straight road is an example of dynamic equilibrium.
Why is it important to consider both net force and net torque for complete equilibrium?
Considering both net force and net torque is crucial because they govern different aspects of an object's motion. Net force determines translational acceleration (change in linear velocity), while net torque determines rotational acceleration (change in angular velocity).
For an object to be in complete equilibrium, it must not be accelerating translationally or rotationally. Thus, both the net force and the net torque must be zero to ensure constant linear and angular velocities, respectively.
Can an object be in equilibrium if there are many forces acting on it?
Absolutely, yes! In fact, most real-world equilibrium scenarios involve multiple forces. The key condition for equilibrium is that the vector sum of all these forces must be zero (translational equilibrium), and the vector sum of all torques must also be zero (rotational equilibrium).
Individual forces can be quite large, but if they perfectly cancel each other out, the object remains in equilibrium. Think of a tug-of-war where both teams pull with equal force – the rope is in equilibrium despite significant forces acting on it.
How do I choose the 'pivot point' when calculating torques for rotational equilibrium?
The choice of the pivot point is entirely arbitrary for an object in rotational equilibrium; the net torque will be zero about any point. However, a strategic choice can significantly simplify calculations.
It's often best to choose the pivot point at the location where an unknown force acts. This is because the torque produced by a force acting at the pivot point itself is zero (since the moment arm is zero), effectively removing that unknown force from the torque equation.
This reduces the number of variables you need to solve for in that particular equation.
What is the difference between stable, unstable, and neutral equilibrium?
These terms describe the stability of an object in static equilibrium when slightly displaced. In stable equilibrium, if you slightly displace the object, it tends to return to its original position (e.
g., a ball in a bowl). Its center of gravity is at a minimum. In unstable equilibrium, a slight displacement causes the object to move further away from its original position (e.g., a ball on top of a hill).
Its center of gravity is at a maximum. In neutral equilibrium, a slight displacement results in the object finding a new equilibrium position (e.g., a ball on a flat surface). Its center of gravity remains at the same height.