Vector Addition — Explained
Detailed Explanation
In physics, quantities are broadly classified into scalars and vectors. Scalars are quantities that possess only magnitude, such as mass, time, temperature, and distance. Vectors, on the other hand, are quantities that possess both magnitude and direction, such as displacement, velocity, acceleration, force, and momentum.
When dealing with vector quantities, simple arithmetic addition is insufficient because the directions of the quantities must also be taken into account. This necessity gives rise to the concept of vector addition.
Conceptual Foundation of Vector Addition
Vector addition is the process of finding a single vector, called the resultant vector, which produces the same effect as the combined action of two or more individual vectors. The resultant vector is essentially the 'sum' of the individual vectors, but this sum is not a simple algebraic sum of their magnitudes. Instead, it's a geometrical sum that considers both magnitudes and directions.
Imagine an object subjected to multiple forces. To understand its net motion, we need to find the single equivalent force that would produce the same acceleration. This equivalent force is the resultant of all individual forces acting on the object. Similarly, if an object undergoes multiple displacements, its final position relative to its starting point is given by the resultant displacement vector.
Key Principles and Laws of Vector Addition
There are several fundamental laws that govern vector addition, primarily graphical methods, which provide a visual understanding, and the analytical method, which offers precision.
1. Triangle Law of Vector Addition
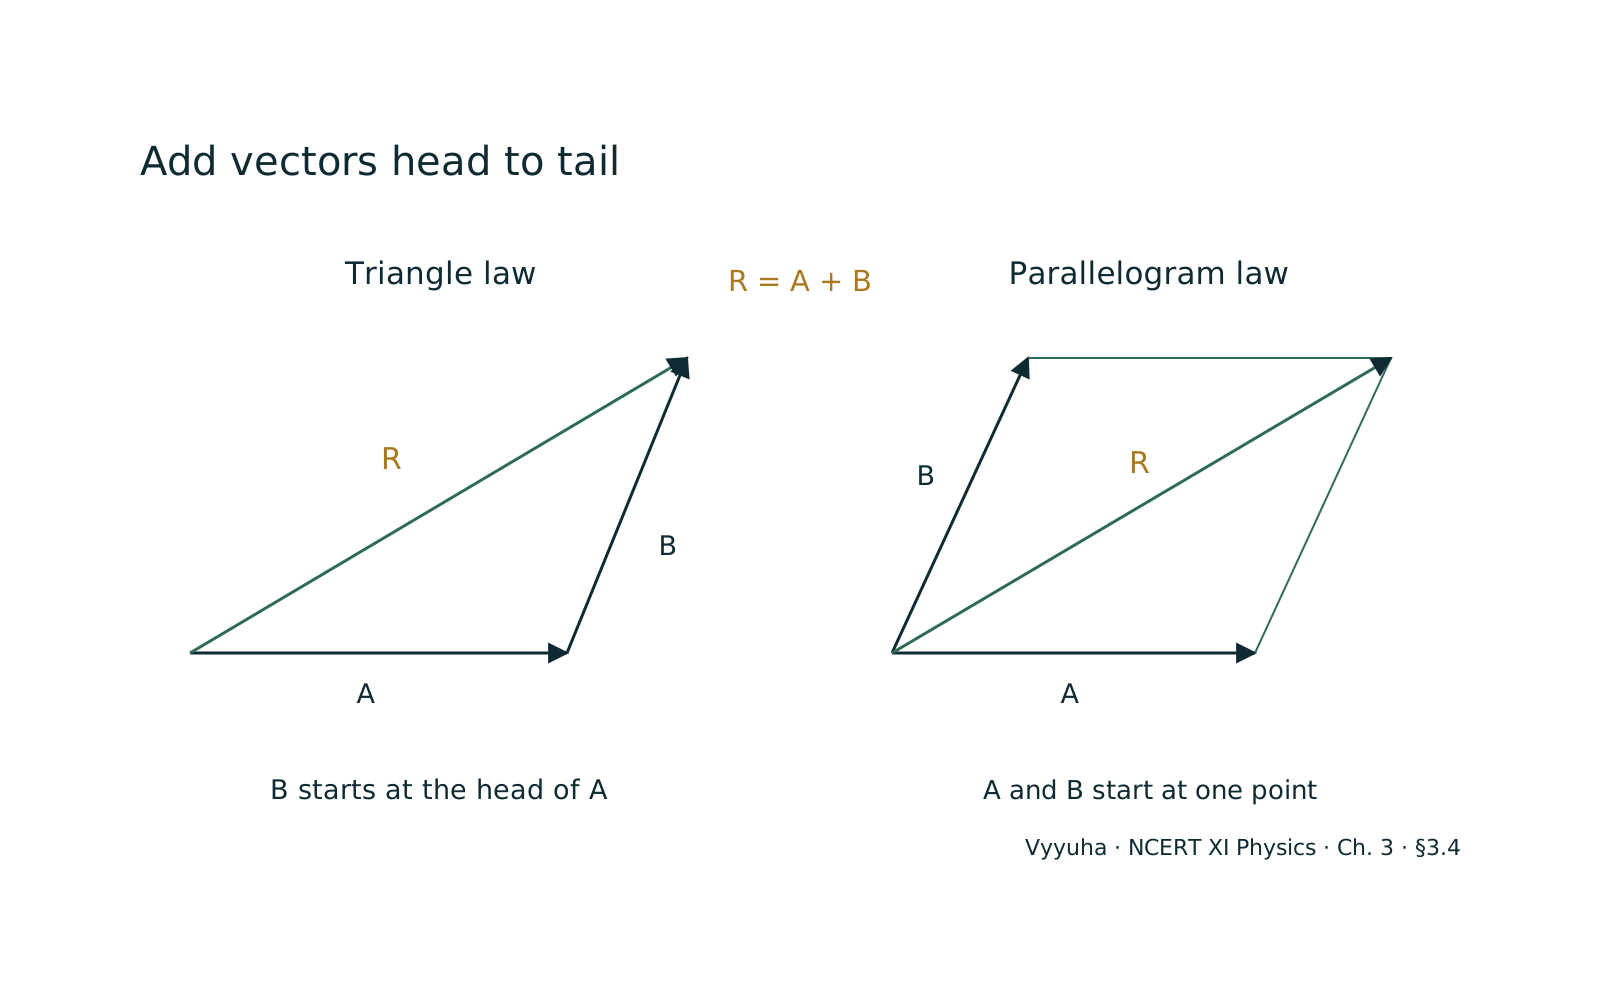
This law is applicable when adding two vectors. If two vectors can be represented in magnitude and direction by the two sides of a triangle taken in the same order, then their resultant is represented in magnitude and direction by the third side of the triangle taken in the opposite order.
Let and be two vectors. To add them using the Triangle Law:
- Draw vector to scale in its given direction.
- From the head (tip) of vector , draw vector to scale in its given direction.
- The resultant vector is drawn from the tail of to the head of .
Mathematically, .
The magnitude of the resultant vector can be found using the Law of Cosines:
Note that in the triangle law construction, the angle between the vectors is actually if is the angle between them when placed tail-to-tail. If is the angle between and when is placed at the head of , then the formula becomes , where is the angle between and when placed head-to-tail.
However, the standard formula uses as the angle between the two vectors when placed tail-to-tail, which is more common in the parallelogram law context.
The direction of the resultant can be found using the Law of Sines or by resolving components.
2. Parallelogram Law of Vector Addition
This law is also for adding two vectors. If two vectors acting simultaneously at a point can be represented in magnitude and direction by the two adjacent sides of a parallelogram drawn from a common point, then their resultant is represented in magnitude and direction by the diagonal of the parallelogram passing through that common point.
Let and be two vectors originating from a common point. To add them using the Parallelogram Law:
- Draw vector and vector from a common origin, representing the adjacent sides of a parallelogram.
- Complete the parallelogram by drawing lines parallel to and .
- The resultant vector is the diagonal drawn from the common origin to the opposite vertex of the parallelogram.
Mathematically, .
The magnitude of the resultant vector is given by:
The direction of the resultant with respect to (let's say ) can be found using:
3. Polygon Law of Vector Addition
This is an extension of the Triangle Law for adding more than two vectors. If a number of vectors can be represented in magnitude and direction by the sides of an open polygon taken in the same order, then their resultant is represented in magnitude and direction by the closing side of the polygon taken in the opposite order.
To add vectors :
- Draw .
- From the head of , draw .
- From the head of , draw .
- From the head of , draw .
- The resultant is drawn from the tail of to the head of .
Mathematically, .
Analytical Method (Component Method)
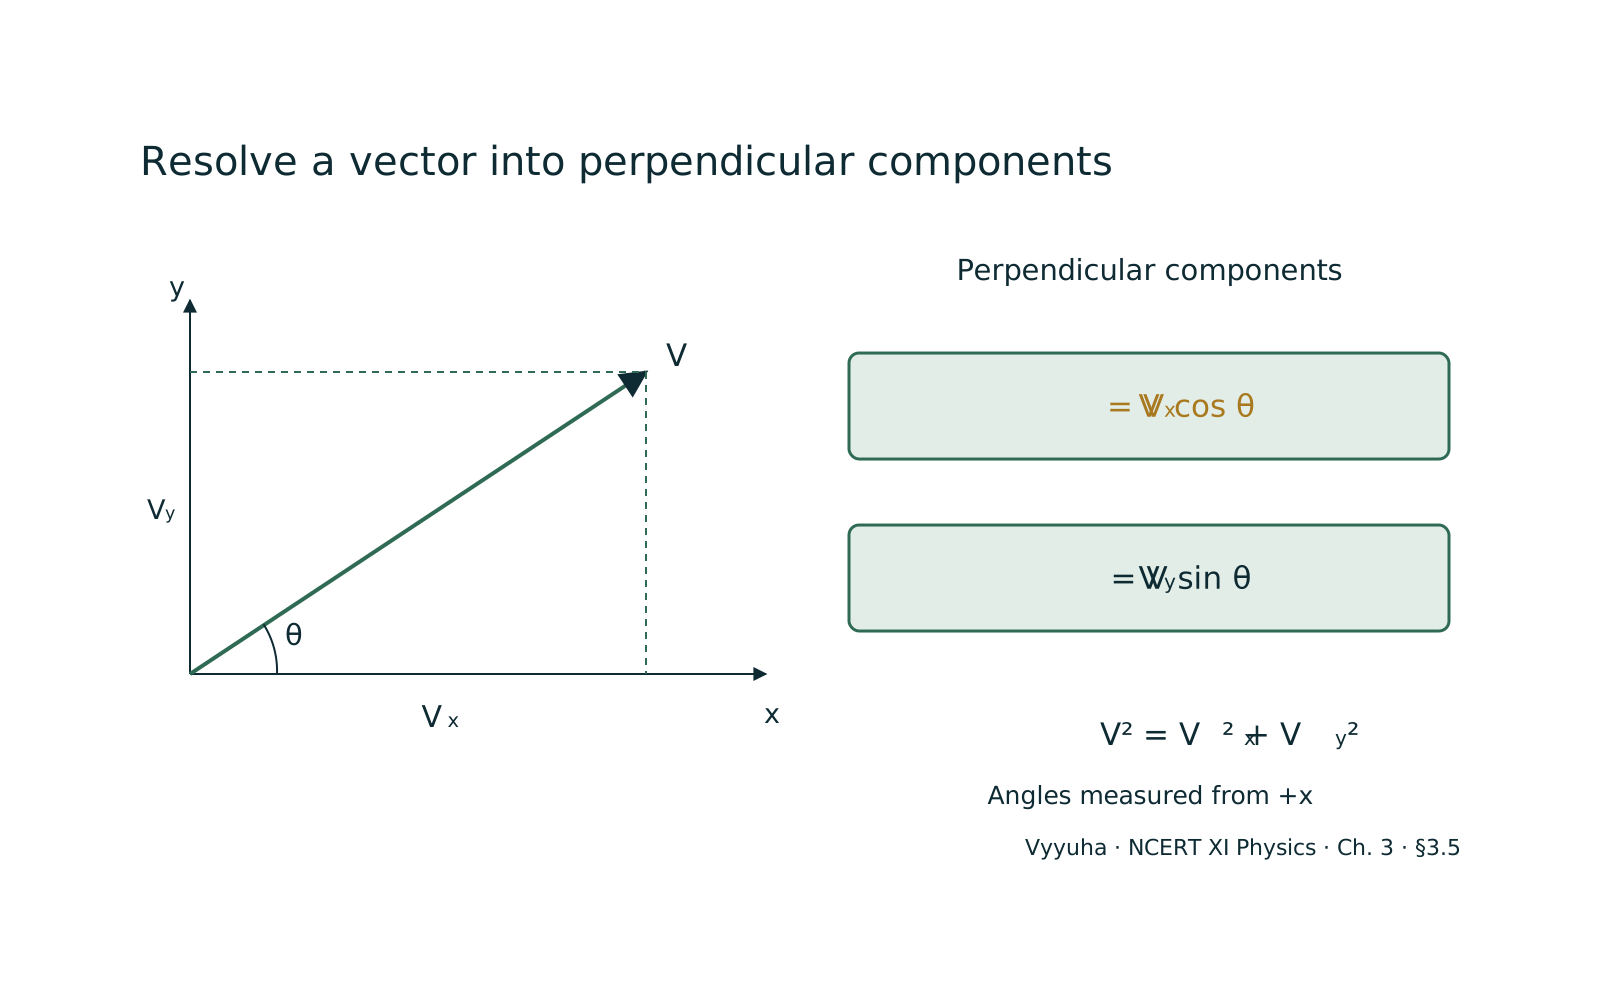
This is the most powerful and widely used method for adding multiple vectors, especially in NEET problems, as it provides precise numerical results without relying on scale drawings. The core idea is to resolve each vector into its mutually perpendicular components (usually along the x and y axes for 2D problems, or x, y, and z axes for 3D problems).
- Resolution of Vectors: — Any vector can be resolved into its components along the x and y axes. If makes an angle with the positive x-axis, its components are:
* * The vector can be written as , where and are unit vectors along the x and y axes, respectively.
- Summing Components: — For a set of vectors , find the x and y components of each vector. Then, sum all the x-components to get the resultant x-component () and all the y-components to get the resultant y-component ().
* *
- Finding Resultant Magnitude and Direction: — The resultant vector can be expressed as .
* The magnitude of the resultant is given by Pythagoras theorem:
Properties of Vector Addition
- Commutative Law: — The order of addition does not affect the resultant. .
- Associative Law: — When adding three or more vectors, the grouping of vectors does not affect the resultant. .
- Distributive Law (Scalar Multiplication): — A scalar multiplied by the sum of vectors is equal to the sum of the scalar multiplied by individual vectors. .
- Existence of Additive Identity (Null Vector): — There exists a null vector (or zero vector) such that . A null vector has zero magnitude and arbitrary direction.
- Existence of Additive Inverse (Negative Vector): — For every vector , there exists a negative vector such that . The negative vector has the same magnitude but opposite direction.
Vector Subtraction
Vector subtraction is a special case of vector addition. Subtracting vector from vector is equivalent to adding the negative of vector to vector . . Graphically, is a vector with the same magnitude as but pointing in the opposite direction. Then, apply the Triangle Law or Parallelogram Law to and .
Real-World Applications
Vector addition is fundamental to many areas of physics:
- Displacement: — Finding the net change in position after multiple movements.
- Velocity: — Determining the resultant velocity of an object when it has its own velocity and is also moving in a medium (e.g., boat in a river, airplane in wind).
- Force: — Calculating the net force (resultant force) acting on an object, which determines its acceleration according to Newton's second law ().
- Acceleration: — Combining different accelerations (e.g., centripetal and tangential acceleration).
- Momentum: — Summing momenta in collisions.
Common Misconceptions
- Adding Magnitudes Directly: — Students often mistakenly add the magnitudes of vectors arithmetically, ignoring their directions. For example, if two forces of 5 N and 3 N act on an object, the resultant is not always 8 N; it can range from 2 N (if opposite) to 8 N (if parallel) or anything in between.
- Incorrect Angle Usage: — In the parallelogram law formula, is the angle between the two vectors when their tails are joined. Using the internal angle of the parallelogram or the angle formed by head-to-tail placement can lead to errors.
- Confusing Scalar and Vector Operations: — Applying scalar rules to vector quantities (e.g., thinking always means ).
- Ignoring Quadrant for Direction: — When finding the direction using , it's crucial to consider the signs of and to place the resultant vector in the correct quadrant.
NEET-Specific Angle
For NEET, the analytical (component) method is paramount. Questions frequently involve:
- Finding resultant of multiple forces/velocities: — Often requiring resolution into components and then summing them.
- Relative velocity problems: — These are essentially vector subtraction problems, where .
- Equilibrium of forces: — If an object is in equilibrium, the vector sum of all forces acting on it is zero (). This means and .
- Projectile motion: — Initial velocity is resolved into horizontal and vertical components.
- Circular motion: — Understanding how centripetal and tangential acceleration vectors add up.
Mastering the component method, understanding the range of possible resultant magnitudes, and correctly applying trigonometric functions are key to success in NEET questions related to vector addition.
Often confused with
Side-by-side differences the NEET paper likes to test.
| Aspect | Vector Addition | Scalar Addition |
|---|---|---|
| Nature of Quantity | Involves vector quantities (magnitude + direction) | Involves scalar quantities (magnitude only) |
| Method of Summation | Geometric summation (considers angles) | Algebraic summation (simple arithmetic) |
| Resultant Range | Resultant magnitude can vary between $|A-B|$ and $|A+B|$ for two vectors. | Resultant magnitude is always the direct sum of individual magnitudes. |
| Example | Displacement: 5 km East + 3 km West = 2 km East | Distance: 5 km + 3 km = 8 km |
| Mathematical Representation | $\vec{A} + \vec{B} = \vec{R}$ (vector notation) | $a + b = c$ (scalar notation) |
The fundamental distinction between vector addition and scalar addition lies in the nature of the quantities being combined. Vector addition accounts for both magnitude and direction, leading to a geometric sum where the orientation of vectors significantly influences the resultant.
Scalar addition, conversely, is a straightforward arithmetic sum of magnitudes, as direction is irrelevant for scalar quantities. This means the range of possible resultant values is much broader for vector addition, depending on the angles between the vectors, whereas scalar addition always yields a single, direct sum.
Why it is tested: NEET relevance: Understanding this difference is crucial for correctly applying physical laws. Misinterpreting a vector sum as a scalar sum is a common error that leads to incorrect answers in problems involving forces, velocities, and displacements, which are core to NEET Physics.
Questions students ask
6 answered on this topic.
What is the difference between scalar addition and vector addition?
Scalar addition is a simple arithmetic sum of magnitudes, applicable to quantities like mass or time, where direction is irrelevant. For example, 2 kg + 3 kg = 5 kg. Vector addition, however, involves combining quantities that have both magnitude and direction, such as displacement or force.
It's a geometric sum where the directions of the vectors significantly influence the resultant. For instance, adding a 5 N force and a 3 N force can yield a resultant anywhere between 2 N and 8 N, depending on the angle between them.
Why can't we just add the magnitudes of vectors to find the resultant?
We cannot simply add magnitudes because vectors represent quantities with direction. If you walk 5 meters east and then 5 meters west, your total displacement is 0 meters, not 10 meters. The directions cancel each other out. Vector addition accounts for this directional aspect. The resultant is the single vector that produces the same overall effect as the individual vectors, which is only possible by considering both their magnitudes and their relative orientations in space.
When is the magnitude of the resultant of two vectors maximum and minimum?
The magnitude of the resultant of two vectors, say and , is maximum when they act in the same direction (angle ). In this case, the resultant magnitude is . It is minimum when they act in opposite directions (angle ). Here, the resultant magnitude is . For any other angle between and , the resultant magnitude will lie between these two extreme values.
What is a null vector and why is it important in vector addition?
A null vector, or zero vector, is a vector with zero magnitude and an arbitrary or undefined direction. It is important because it acts as the additive identity in vector algebra, meaning . It also represents the resultant when two equal and opposite vectors are added (), or when an object returns to its starting point after multiple displacements, resulting in zero net displacement.
How does vector subtraction relate to vector addition?
Vector subtraction is essentially a specialized form of vector addition. Subtracting vector from vector is equivalent to adding the negative of vector to vector . The negative of a vector, , has the same magnitude as but points in the exact opposite direction. So, . This transformation allows us to use the same graphical or analytical methods developed for addition to solve subtraction problems.
Can vector addition be used to find the equilibrium of forces?
Yes, absolutely. The concept of vector addition is central to understanding equilibrium. If an object is in equilibrium, it means the net force acting on it is zero. In vector terms, this implies that the vector sum of all individual forces acting on the object must be a null vector (). This condition is often broken down into components, meaning the sum of all x-components of forces must be zero, and similarly for y-components (and z-components in 3D).