Motion in a Plane
Motion in a plane, often referred to as two-dimensional motion, describes the movement of an object confined to a single flat surface. This type of motion requires the use of vector quantities to accurately represent physical parameters such as position, displacement, velocity, and acceleration, as these quantities possess both magnitude and direction within the plane. Key examples include project…
Quick Summary
Motion in a plane, or two-dimensional motion, describes the movement of an object confined to a flat surface. It necessitates the use of vectors, which possess both magnitude and direction, to represent physical quantities like position, displacement, velocity, and acceleration.
A position vector defines an object's location. Displacement is the change in position, while velocity is the rate of change of position, and acceleration is the rate of change of velocity.
A crucial principle is the independence of perpendicular motions: horizontal and vertical components of motion can be analyzed separately, with time being the common link. Key examples include projectile motion, where an object follows a parabolic path under gravity, and uniform circular motion, where an object moves in a circle at constant speed but continuously changing velocity due to centripetal acceleration.
Relative velocity in 2D involves vector subtraction to find the velocity of one object with respect to another, vital for problems like river crossings or rain falling on a moving person.
Full explanation
Motion in a plane is a fundamental concept in kinematics, extending the principles of one-dimensional motion to two dimensions. It involves understanding how objects move when their paths are confined to a flat surface, requiring a vector-based approach to describe their position, displacement, velocity, and acceleration. This section will delve into the conceptual foundation, key principles, derivations, applications, common misconceptions, and the NEET-specific angle for this crucial topic.
Conceptual Foundation
- Vectors and Scalars — Before diving into 2D motion, a solid understanding of vectors is paramount. Scalars are quantities defined solely by magnitude (e.g., mass, time, speed, distance). Vectors are quantities defined by both magnitude and direction (e.g., displacement, velocity, acceleration, force). In 2D, vectors are typically represented using components along two perpendicular axes, usually x and y. A vector can be written as , where and are its components along the x and y axes, and and are unit vectors in those respective directions.
* Vector Addition/Subtraction: Vectors are added or subtracted component-wise. If and , then .
Graphically, this is done using the triangle or parallelogram law. * Vector Resolution: Any vector can be resolved into its perpendicular components. If a vector makes an angle with the x-axis, its components are and .
- Position, Displacement, Velocity, and Acceleration Vectors — These are the core kinematic quantities in 2D motion.
* **Position Vector ()**: Locates an object relative to the origin. . * **Displacement Vector ()**: Change in position. .
* **Velocity Vector ()**: Rate of change of position. . The direction of the instantaneous velocity vector is always tangent to the path of motion.
* **Acceleration Vector ()**: Rate of change of velocity. .
Key Principles/Laws
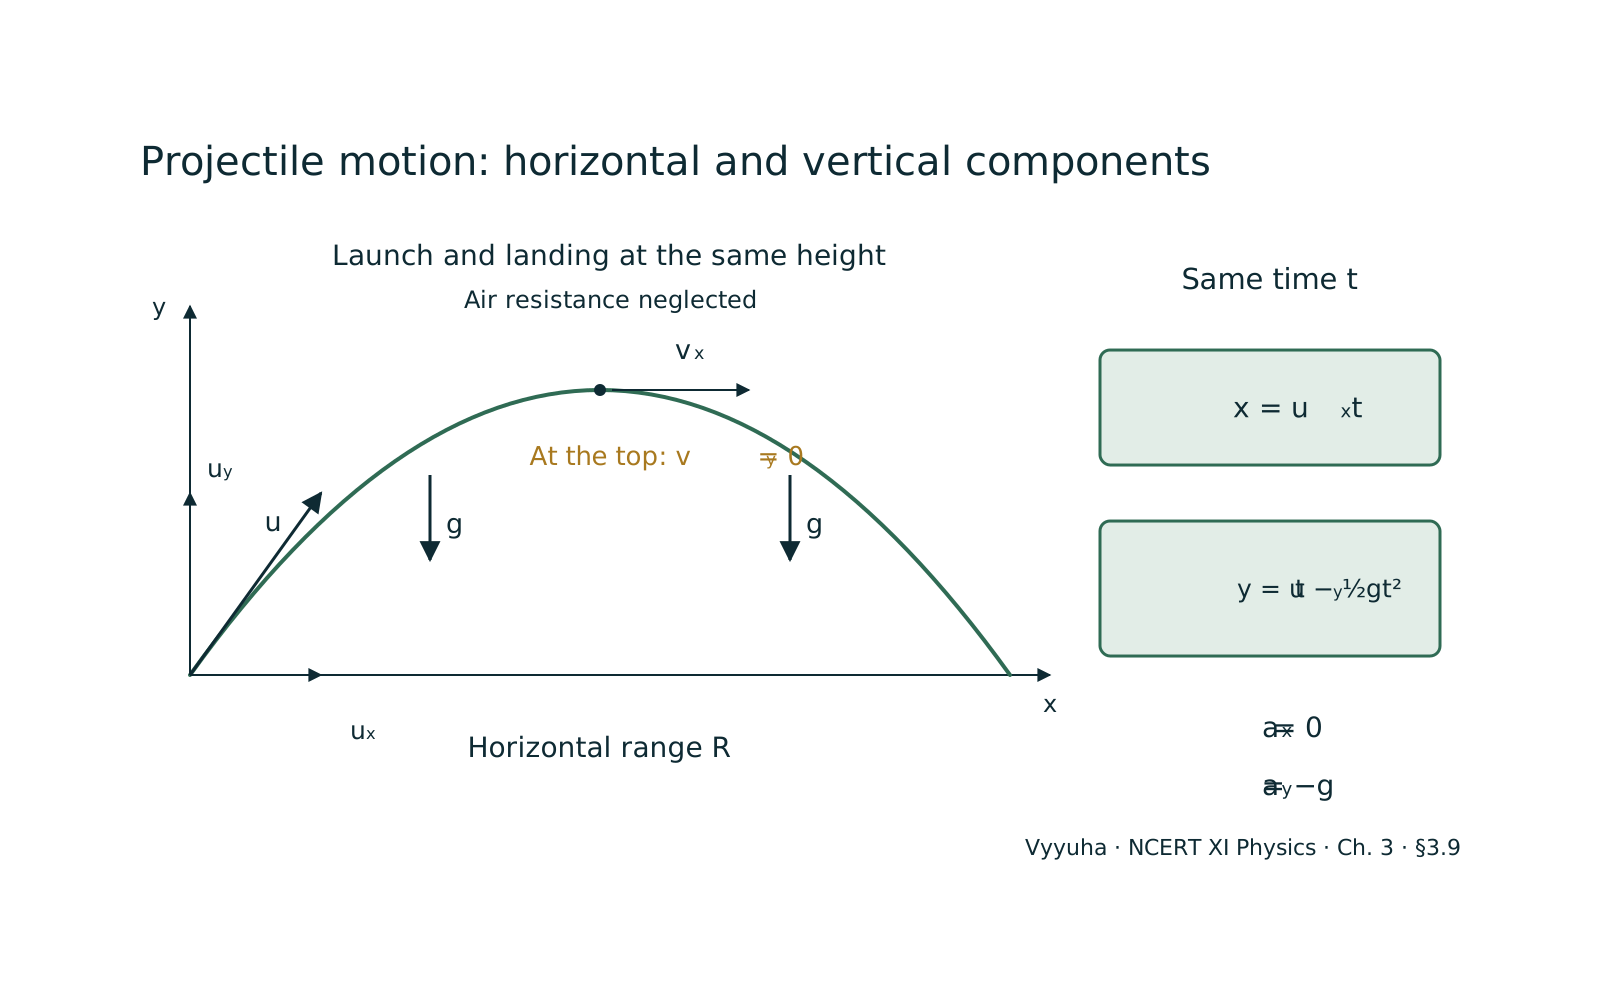
- Independence of Perpendicular Motions — This is the cornerstone of 2D kinematics. The motion along the x-axis is entirely independent of the motion along the y-axis. This means we can apply the 1D kinematic equations separately to the x and y components of motion. Time is the only quantity that links these two independent motions.
- Equations of Motion for Constant Acceleration in 2D — If the acceleration is constant (i.e., and are constant), we can use the following equations, derived from their 1D counterparts:
* Velocity: * Component form: and * Displacement: * Component form: and * Alternative displacement (if acceleration is constant): and
Derivations and Specific Cases
- Projectile Motion — This is a classic example of motion in a plane under constant acceleration (due to gravity). An object launched into the air and moving freely under gravity's influence is a projectile. Air resistance is usually neglected for NEET problems.
* Assumptions: Constant acceleration (downwards), (no horizontal acceleration). Initial velocity at an angle with the horizontal. So, and .
* Horizontal Motion: (constant velocity)
* Vertical Motion:
* Equation of Trajectory: Eliminating from the and equations: From , we get . Substitute into equation:
* **Time of Flight ()**: The total time the projectile remains in the air. At (ground level), . One solution is (start), the other is .
* **Maximum Height ()**: The highest point reached. At maximum height, . Using : .
* **Horizontal Range ()**: The total horizontal distance covered. . * Maximum range occurs when , which means , so . Thus, at . * For a given speed , ranges are equal for complementary angles .
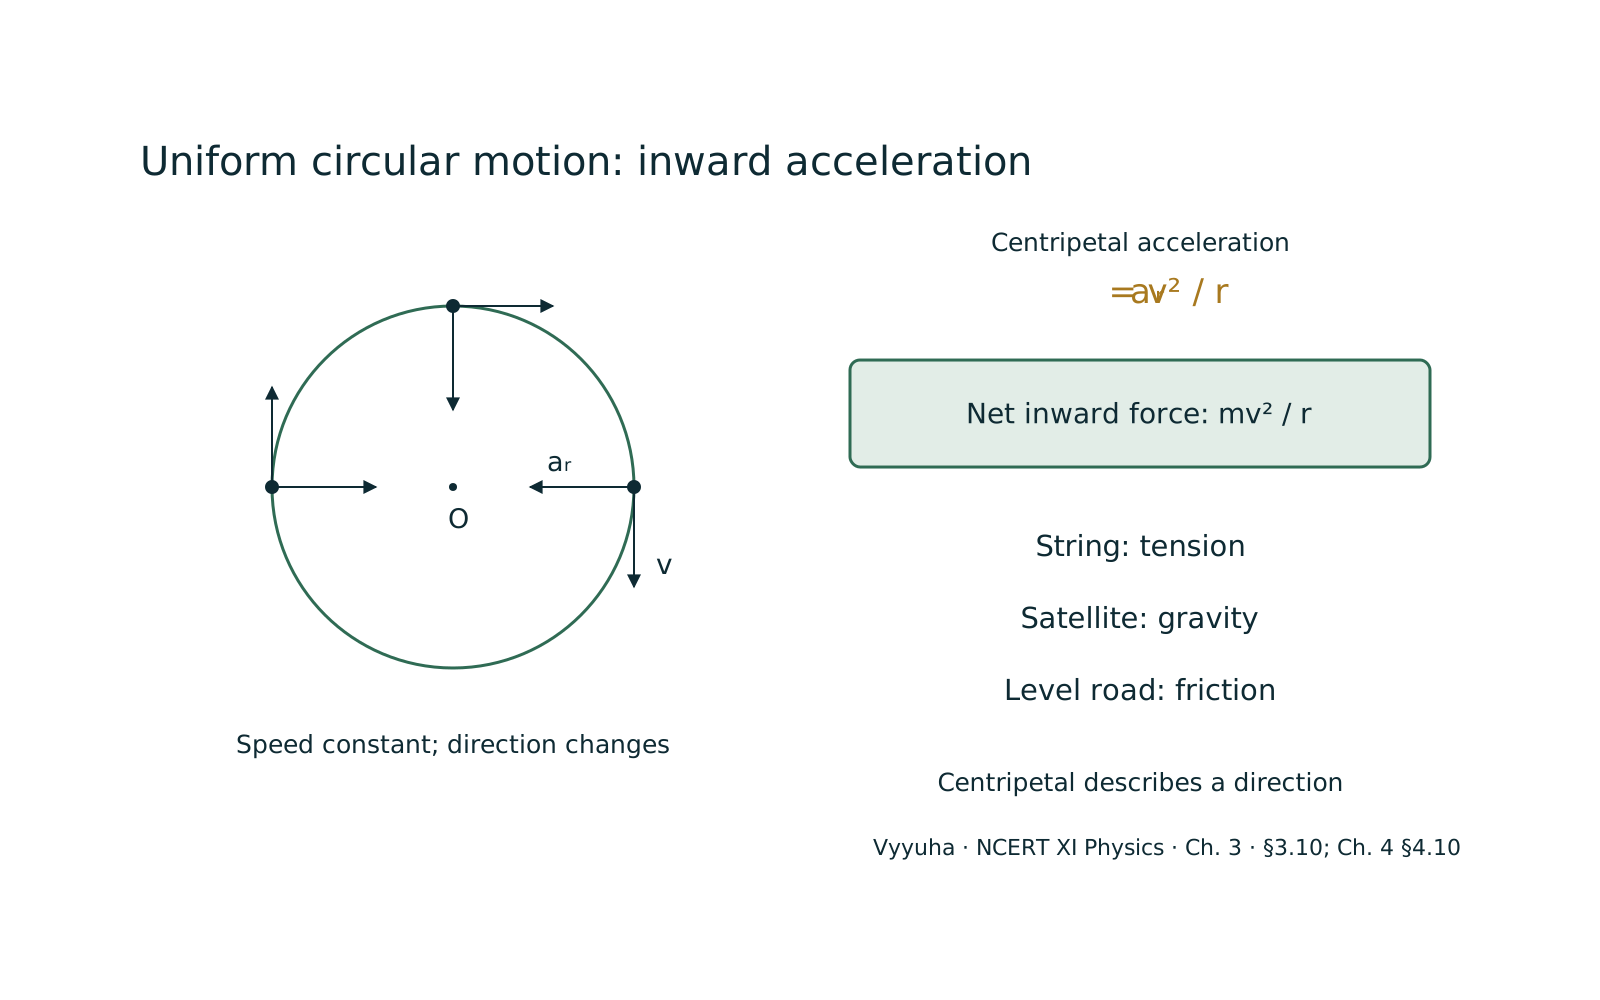
- Uniform Circular Motion (UCM) — Motion of an object along a circular path at a constant speed. While speed is constant, the direction of velocity continuously changes, implying acceleration.
* **Angular Displacement ()**: Angle swept by the radius vector. Unit: radian. * **Angular Velocity ()**: Rate of change of angular displacement. .
Unit: rad/s. For UCM, is constant. Relation to linear speed: . * **Angular Acceleration ()**: Rate of change of angular velocity. . Unit: rad/s.
For UCM, . * **Centripetal Acceleration ()**: The acceleration directed towards the center of the circle, responsible for changing the direction of velocity. Its magnitude is .
This acceleration is always perpendicular to the velocity vector. * **Centripetal Force ()**: The force causing centripetal acceleration. . This is not a new type of force but rather the net force acting towards the center (e.
g., tension, friction, gravity).
- Relative Velocity in 2D — The velocity of an object with respect to another moving object. If is the velocity of object A and is the velocity of object B, then the velocity of A relative to B is . This principle is crucial for problems involving river-boat scenarios or rain-man problems.
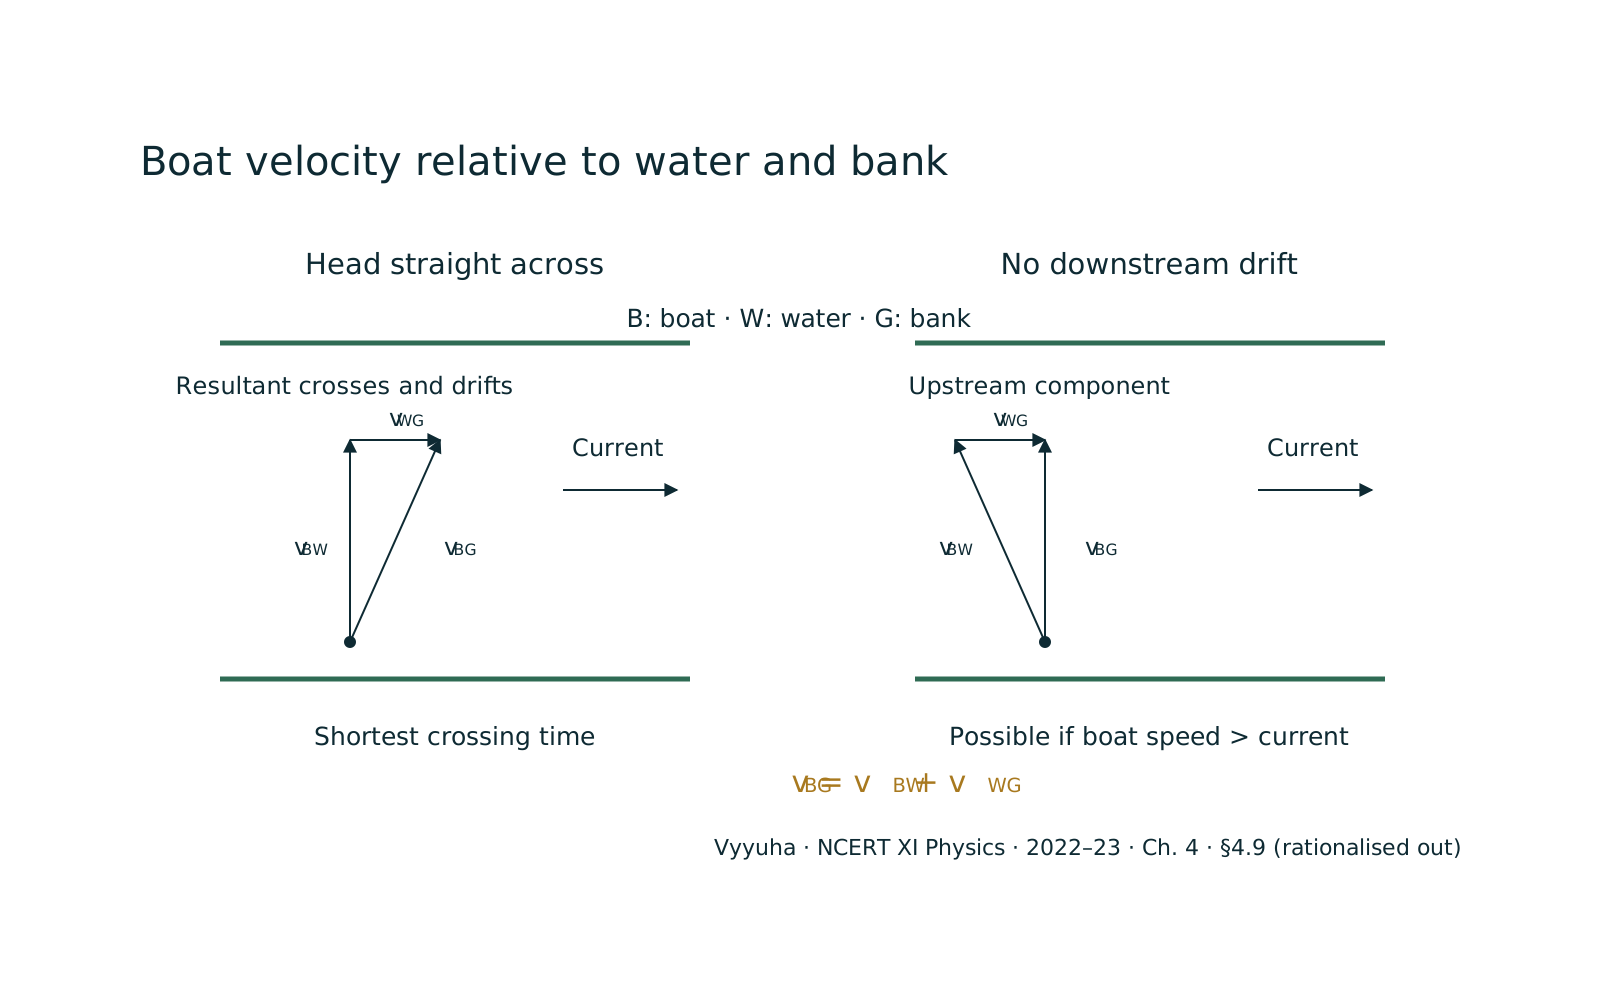
* River-Boat Problems: A boat moving in a river. The velocity of the boat relative to the ground () is the vector sum of the velocity of the boat relative to the water () and the velocity of the water relative to the ground ().
So, . * Shortest Path (across the river): To cross the river directly, the net velocity of the boat relative to the ground must be perpendicular to the river flow.
This requires the boat to be steered upstream at an angle. . Time taken , where is river width. * Shortest Time (across the river): To cross in minimum time, the boat should be steered perpendicular to the river flow.
The time taken is . The boat will drift downstream by a distance . * Rain-Man Problems: The velocity of rain relative to the man () is , where is the velocity of rain relative to the ground and is the velocity of the man relative to the ground.
Real-World Applications
- Sports — Trajectory of a football kick, a basketball shot, or a javelin throw are all examples of projectile motion. Analyzing these helps athletes optimize their performance.
- Military — Ballistics (the study of projectile motion) is critical for artillery and missile guidance systems.
- Engineering — Design of roller coasters (circular motion), bridges (forces in 2D), and aircraft (relative velocity, aerodynamics).
- Astronomy — Orbital motion of planets and satellites around celestial bodies involves principles of circular motion and gravitational forces.
Common Misconceptions
- Confusing Scalar and Vector Quantities — Students often mix up speed with velocity or distance with displacement, especially when calculating average values. Remember, velocity and displacement are vectors, and their directions matter.
- Applying 1D Equations Directly to 2D Motion — While the component-wise approach allows using 1D equations, it's crucial to apply them separately to the x and y components. For instance, applies to and , not directly to the magnitudes of and unless they are collinear.
- Velocity and Acceleration Direction — In UCM, students might think there's no acceleration because speed is constant. However, the direction of velocity changes, which means there is acceleration (centripetal acceleration) directed towards the center. Also, velocity is always tangent to the path, while acceleration can be at any angle to the path (except for straight-line motion).
- Projectile Motion at Max Height — At the maximum height of a projectile's path, only the vertical component of velocity () is zero. The horizontal component () remains constant and non-zero (assuming no air resistance). The acceleration due to gravity () is always present and directed downwards throughout the flight.
- Relative Velocity Sign Errors — When dealing with relative velocity, correctly assigning directions (positive/negative or using unit vectors) and applying the vector subtraction formula () is critical. A common mistake is simply adding velocities when subtraction is required.
NEET-Specific Angle
NEET questions on Motion in a Plane frequently test conceptual understanding alongside problem-solving skills. Expect questions on:
- Projectile Motion — Calculating range, height, time of flight, velocity at a specific point, or angle of projection. Often involves comparing two projectiles or finding conditions for maximum range/height.
- Uniform Circular Motion — Calculating centripetal acceleration/force, relating linear and angular quantities, or identifying the force providing centripetal acceleration.
- Vector Algebra — Basic vector addition, subtraction, dot product (for work/power), cross product (for torque/angular momentum - though less common in kinematics itself), and resolution of vectors.
- Relative Velocity — River-boat and rain-man problems are very common, requiring careful vector addition/subtraction and understanding of shortest path vs. shortest time scenarios.
- Graphical Interpretation — Sometimes, graphs of position, velocity, or acceleration components versus time might be given, requiring interpretation of 2D motion.
Mastering vector manipulation and the independence of perpendicular motions is key to success in this topic. Practice with a variety of numerical problems, paying close attention to units and directions.
Key Concepts
In 2D motion, vectors are often given by their magnitude and direction (angle). To perform operations like…
Projectile motion is characterized by several key parameters: Time of Flight (), Maximum Height (), and…
River crossing problems often involve finding the velocity of a boat relative to the ground ()…
Often confused with
Side-by-side differences the NEET paper likes to test.
| Aspect | Motion in a Plane | Motion in a Straight Line (1D Motion) |
|---|---|---|
| Dimensions | One dimension (along a single axis) | Two dimensions (in a plane, using two perpendicular axes) |
| Vector Representation | Direction often indicated by sign (+/-) | Direction requires angles or unit vectors ($\hat{i}, \hat{j}$) |
| Path of Motion | Always a straight line | Can be curved (e.g., parabolic, circular) or straight |
| Independence of Motion | Not applicable, as there's only one dimension | Horizontal and vertical motions are independent (e.g., in projectile motion) |
| Complexity of Analysis | Simpler, direct application of scalar equations with sign convention | More complex, requires vector algebra, resolution of components, and separate analysis of x and y motions |
| Examples | Car moving on a straight road, ball falling vertically | Projectile motion, uniform circular motion, river-boat problems |
The core distinction between motion in a straight line and motion in a plane lies in the number of spatial dimensions required to describe the movement. One-dimensional motion is restricted to a single axis, simplifying vector directions to positive or negative signs.
In contrast, two-dimensional motion occurs within a plane, demanding full vector notation with components along two perpendicular axes. This allows for curved trajectories and introduces the powerful concept of independent horizontal and vertical motions, making the analysis more intricate but also more versatile for describing real-world phenomena like throwing a ball or orbiting a satellite.
Why it is tested: NEET relevance: Understanding this difference is crucial for correctly applying kinematic equations. Students often make the mistake of directly applying 1D formulas to 2D problems without resolving vectors, leading to incorrect solutions. NEET questions frequently test the independence of perpendicular motions, especially in projectile motion and relative velocity scenarios. A clear grasp helps in choosing the right approach and avoiding conceptual pitfalls.
Questions students ask
6 answered on this topic.
What is the primary difference between motion in a straight line and motion in a plane?
The fundamental difference lies in the number of dimensions required to describe the motion. Motion in a straight line (1D motion) can be fully described using a single coordinate axis, meaning the object's position, velocity, and acceleration are always along that line.
Motion in a plane (2D motion), however, requires two independent coordinate axes (e.g., x and y) to specify the object's position and describe its vector quantities. This means that in 2D motion, the direction of velocity and acceleration can change in two dimensions, leading to more complex paths like parabolas or circles, unlike the purely linear paths in 1D.
Is speed constant in uniform circular motion? What about velocity and acceleration?
In uniform circular motion, the speed of the object is constant. This means the magnitude of its velocity vector remains unchanged. However, the velocity itself is not constant because its direction is continuously changing as the object moves along the circular path.
Since velocity is changing (due to change in direction), there must be an acceleration. This acceleration, known as centripetal acceleration, is always directed towards the center of the circle and is perpendicular to the instantaneous velocity vector.
So, constant speed, but changing velocity and non-zero acceleration.
Why is the horizontal component of velocity constant in projectile motion (neglecting air resistance)?
In projectile motion, once an object is launched, the only significant force acting on it (neglecting air resistance) is gravity, which acts purely in the vertical direction. There are no horizontal forces acting on the projectile.
According to Newton's first law of motion, an object in motion stays in motion with the same speed and in the same direction unless acted upon by an unbalanced force. Since there's no horizontal force, there's no horizontal acceleration, and thus the horizontal component of velocity remains constant throughout the flight.
What are complementary angles in projectile motion, and what is their significance?
Complementary angles in projectile motion are two projection angles that add up to (e.g., and , or and ). For a given initial speed, projectiles launched at complementary angles will have the same horizontal range.
This is because the range formula is . If , then . So, .
Thus, the range remains the same. However, their maximum heights and times of flight will be different.
How do you approach relative velocity problems in two dimensions, like river-boat or rain-man scenarios?
The key to relative velocity problems in 2D is to use vector addition/subtraction. The general formula is , where is the velocity of A relative to B.
For river-boat problems, it's often easier to think of it as . For rain-man problems, .
Always draw a vector diagram, resolve velocities into x and y components if necessary, and then perform the vector operations. Pay close attention to the frame of reference for each velocity vector.
Can an object have zero velocity but non-zero acceleration in 2D motion?
Yes, absolutely. Consider a projectile launched vertically upwards. At its highest point, its vertical velocity component is momentarily zero, but the acceleration due to gravity () is still acting downwards.
Similarly, if a ball is thrown straight up and then falls back down, at the peak of its trajectory, its instantaneous velocity is zero, but the acceleration due to gravity is still downwards.
This principle extends to 2D motion, where at the peak of a projectile's path, the vertical velocity is zero, but horizontal velocity is non-zero, and acceleration due to gravity is still acting.
Revise in 30 seconds
- Position Vector —
- Displacement —
- Velocity —
- Acceleration —
- Equations of Motion (constant $\vec{a}$)
- -
- Projectile Motion (from ground, $u$ at $\theta$)
- , - , - Time of Flight: - Max Height: - Horizontal Range: - Trajectory:
- Uniform Circular Motion (UCM)
- Linear-Angular relation: - Centripetal Acceleration:
- Relative Velocity —
For Projectile Motion formulas, remember 'T-H-R': Time of flight: Two Up Side Gravity () Height: Half Up Side Square Gravity () Range: Up Side Twice Gravity ()
For Relative Velocity, think 'A relative to B is A minus B': . Always remember the 'minus' for relative velocity, and then use vector addition for resultant velocities like .